One autonomous driver, built for the bus.
Ugo is autonomous driving software plus a retrofit kit that interfaces with the vehicle. It is designed for the city buses operators already own, starting on fixed routes.
Explore the Ugo sensor suite
Select a point on the vehicle or a system below. Rotate the model to see how perception, localization, compute and control fit together.
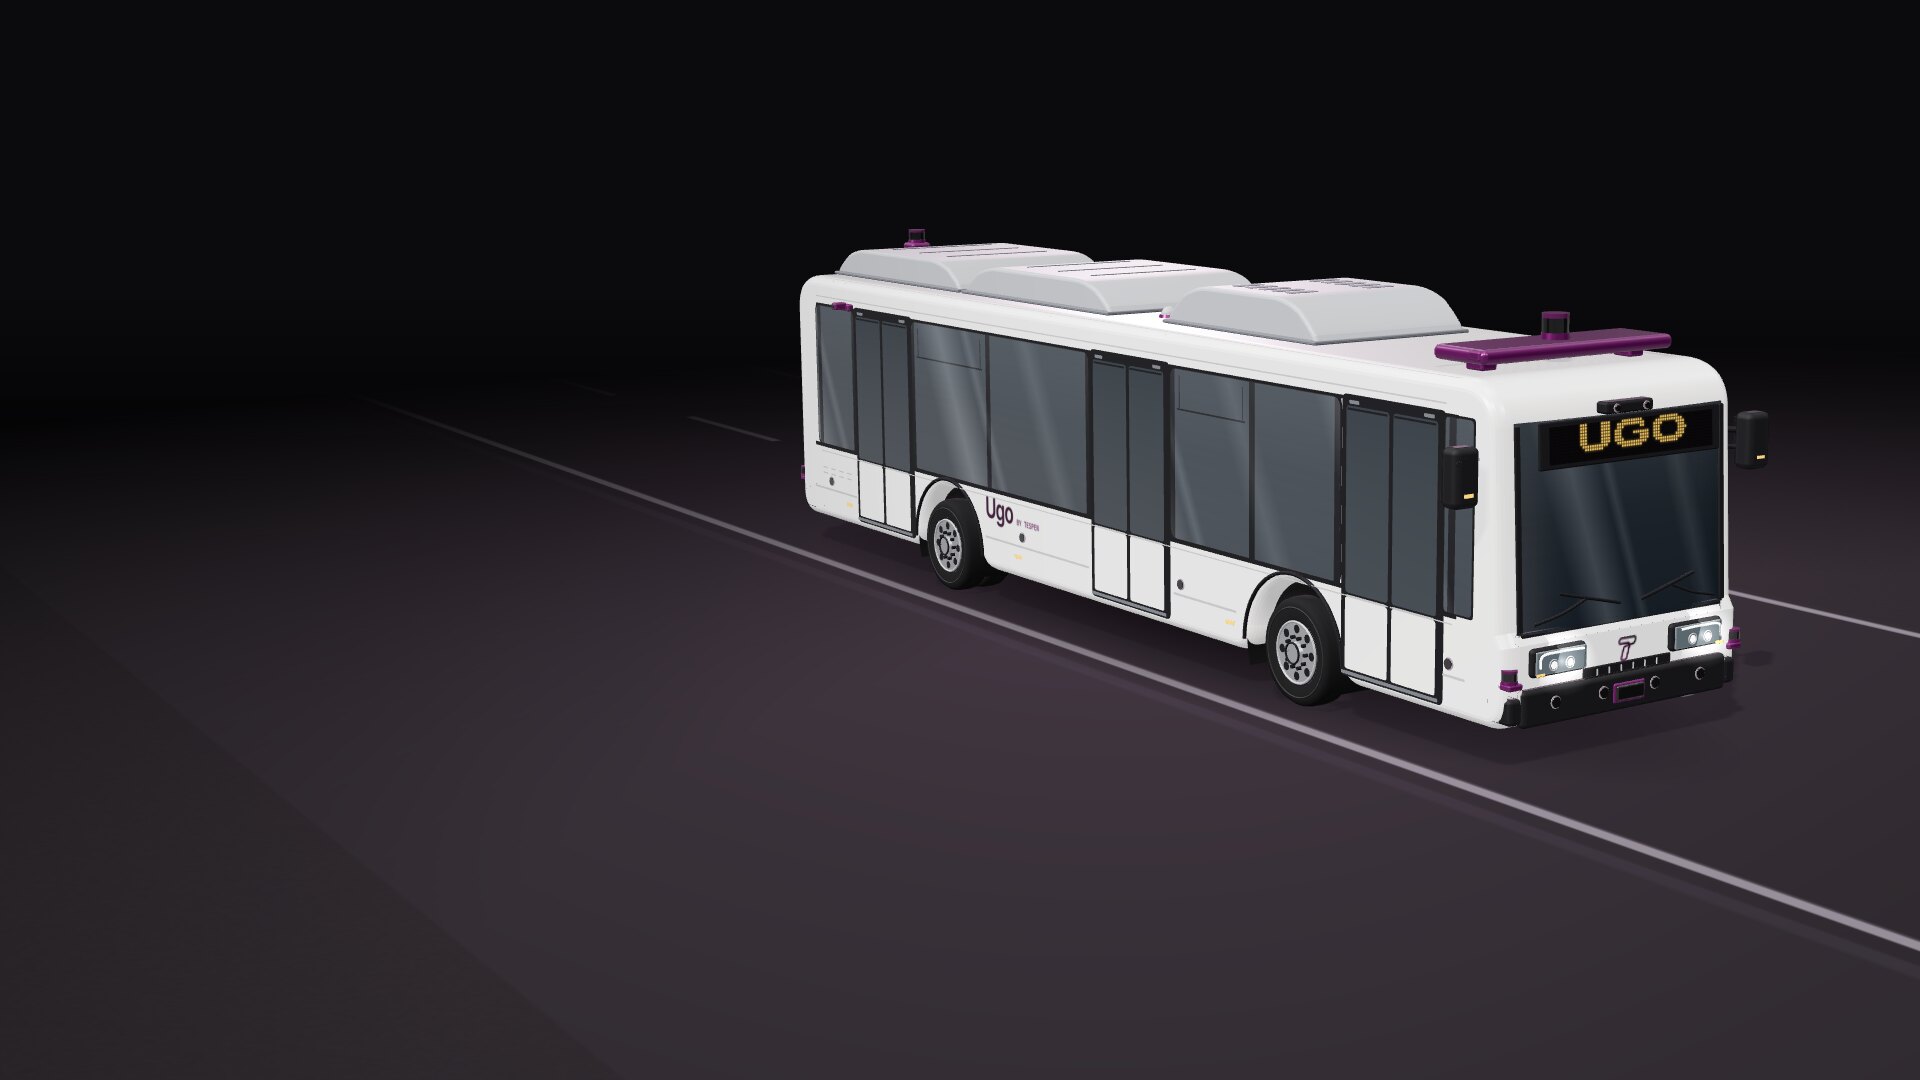
The interactive model is unavailable. The complete sensor suite is described below.
Two parts, one driver
Driving software
Localization, perception, prediction, planning and control, tuned for fixed-route city buses: stops, docking, turns and the road users around them.
Retrofit kit
LiDAR, cameras, radar and close-range sensors; GNSS and motion sensing; onboard compute; and an interface to the vehicle’s steering, braking and propulsion. Off-the-shelf hardware wherever possible.
How it drives
Sense
LiDAR, cameras, radar, ultrasonics, GNSS and motion sensing build a picture of the bus and the street around it.
Plan
The software places the bus on a map of the route, predicts what other road users will do next and plans a safe path and speed.
Act
Through the retrofit kit, the plan becomes steering, braking and propulsion commands on the vehicle itself.
Which buses first
We start with newer low-floor city buses, where braking and propulsion are already electronic. Battery-electric fleets are the natural first target.
Each vehicle model is qualified once. After that, the same work applies to every bus of that model in the fleet.
Operators keep their vehicles and depots; Ugo adds the driver.